
Control systems
Learn how commands, sensors, and feedback affect robot motion
Motor commands
A control system turns a goal into a action. For example, pushing a gamepad stick gives the a command. Asking an arm to hold a position gives its a target.
Check whether the program measures the motion produced by its command.
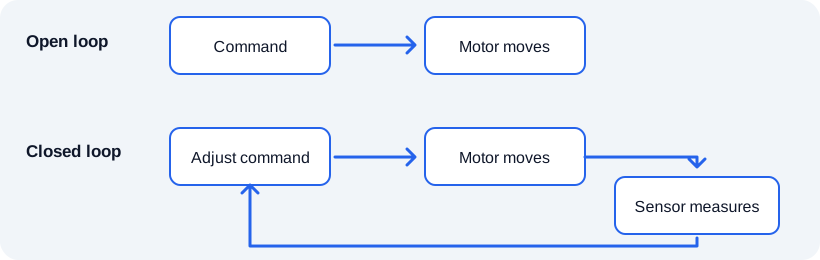
Open-loop control
Suppose your code sets an arm motor to 0.3 power for half a second. The program has sent a command, but it has not measured the arm's final position. Battery , friction, or an added game piece can change where it stops.
Open-loop control is a good first step for learning motor direction and power. It can also work when exact position is unimportant. Test it at low power before using it on a .
Closed-loop control
Now suppose the arm has an . Your code compares the target position with the measured position and changes motor power based on the difference. That difference is called the error.
| If the arm is… | The controller can… |
|---|---|
| Below its target | Move it upward |
| Above its target | Move it downward |
| Near its target | Reduce power or hold position |
Feedback helps a robot correct for changing conditions, but it needs a trustworthy measurement and careful tuning. A reading alone does not make an action accurate.
Learning order
- Joystick mapping: turn driver input into motor commands.
- PID control: use error to correct a motor or mechanism.
- Motion profiling: choose smoother target motion.
- Low-pass filtering: reduce noise in a measurement.
- Kalman filtering: combine predictions and measurements when simpler filters are not enough.
You do not need to master every technique at once. Begin with one motor and one measurement; add complexity only after you can observe what the robot is doing.
For gravity-loaded mechanisms, continue from to Feedforward.
For a drivetrain, Field-centric drive connects driver input to a heading measurement. For a shooter, Flywheel velocity control covers encoder units, controller choice, and measured recovery before feeding.
Once the mechanism's measurements and limits are reliable, system identification explains how to fit and validate a voltage model from test data. Keep the resulting units and hardware configuration with the coefficients.